A custom 3D-printed robotic radar mapping system designed to scan 180° spatial arcs, streaming live sonar telemetry over Serial for real-time PC visualization.
This project combines custom mechanical design, microcontroller firmware, and a real-time host application to deliver sonar mapping capability in a compact form factor.
Emits ultrasonic pulses (40 kHz)
Calculates distance and servo angle
Renders the sweep vector and target blips
HC-SR04 sonar transducer measuring echo delay to detect targets up to 400 cm away with 3 mm precision.
SG90 micro servo providing smooth PWM-controlled positional movement across a continuous 180° sweep.
Custom PLA robot head chassis designed to retain the sonar sensor, organize wiring, and mount firmly onto the servo base.
Desktop radar application rendering real-time polar sweep vectors, range rings, and persistent object decay blips.
Explore the physical build, hardware details, and live radar tracking in action.
Watch the 3D-printed robot head sweep back and forth while sending real-time distance telemetry to the desktop application. As a blue 3D cone is detected in front of the scanner, green target blips illuminate on the radar screen.
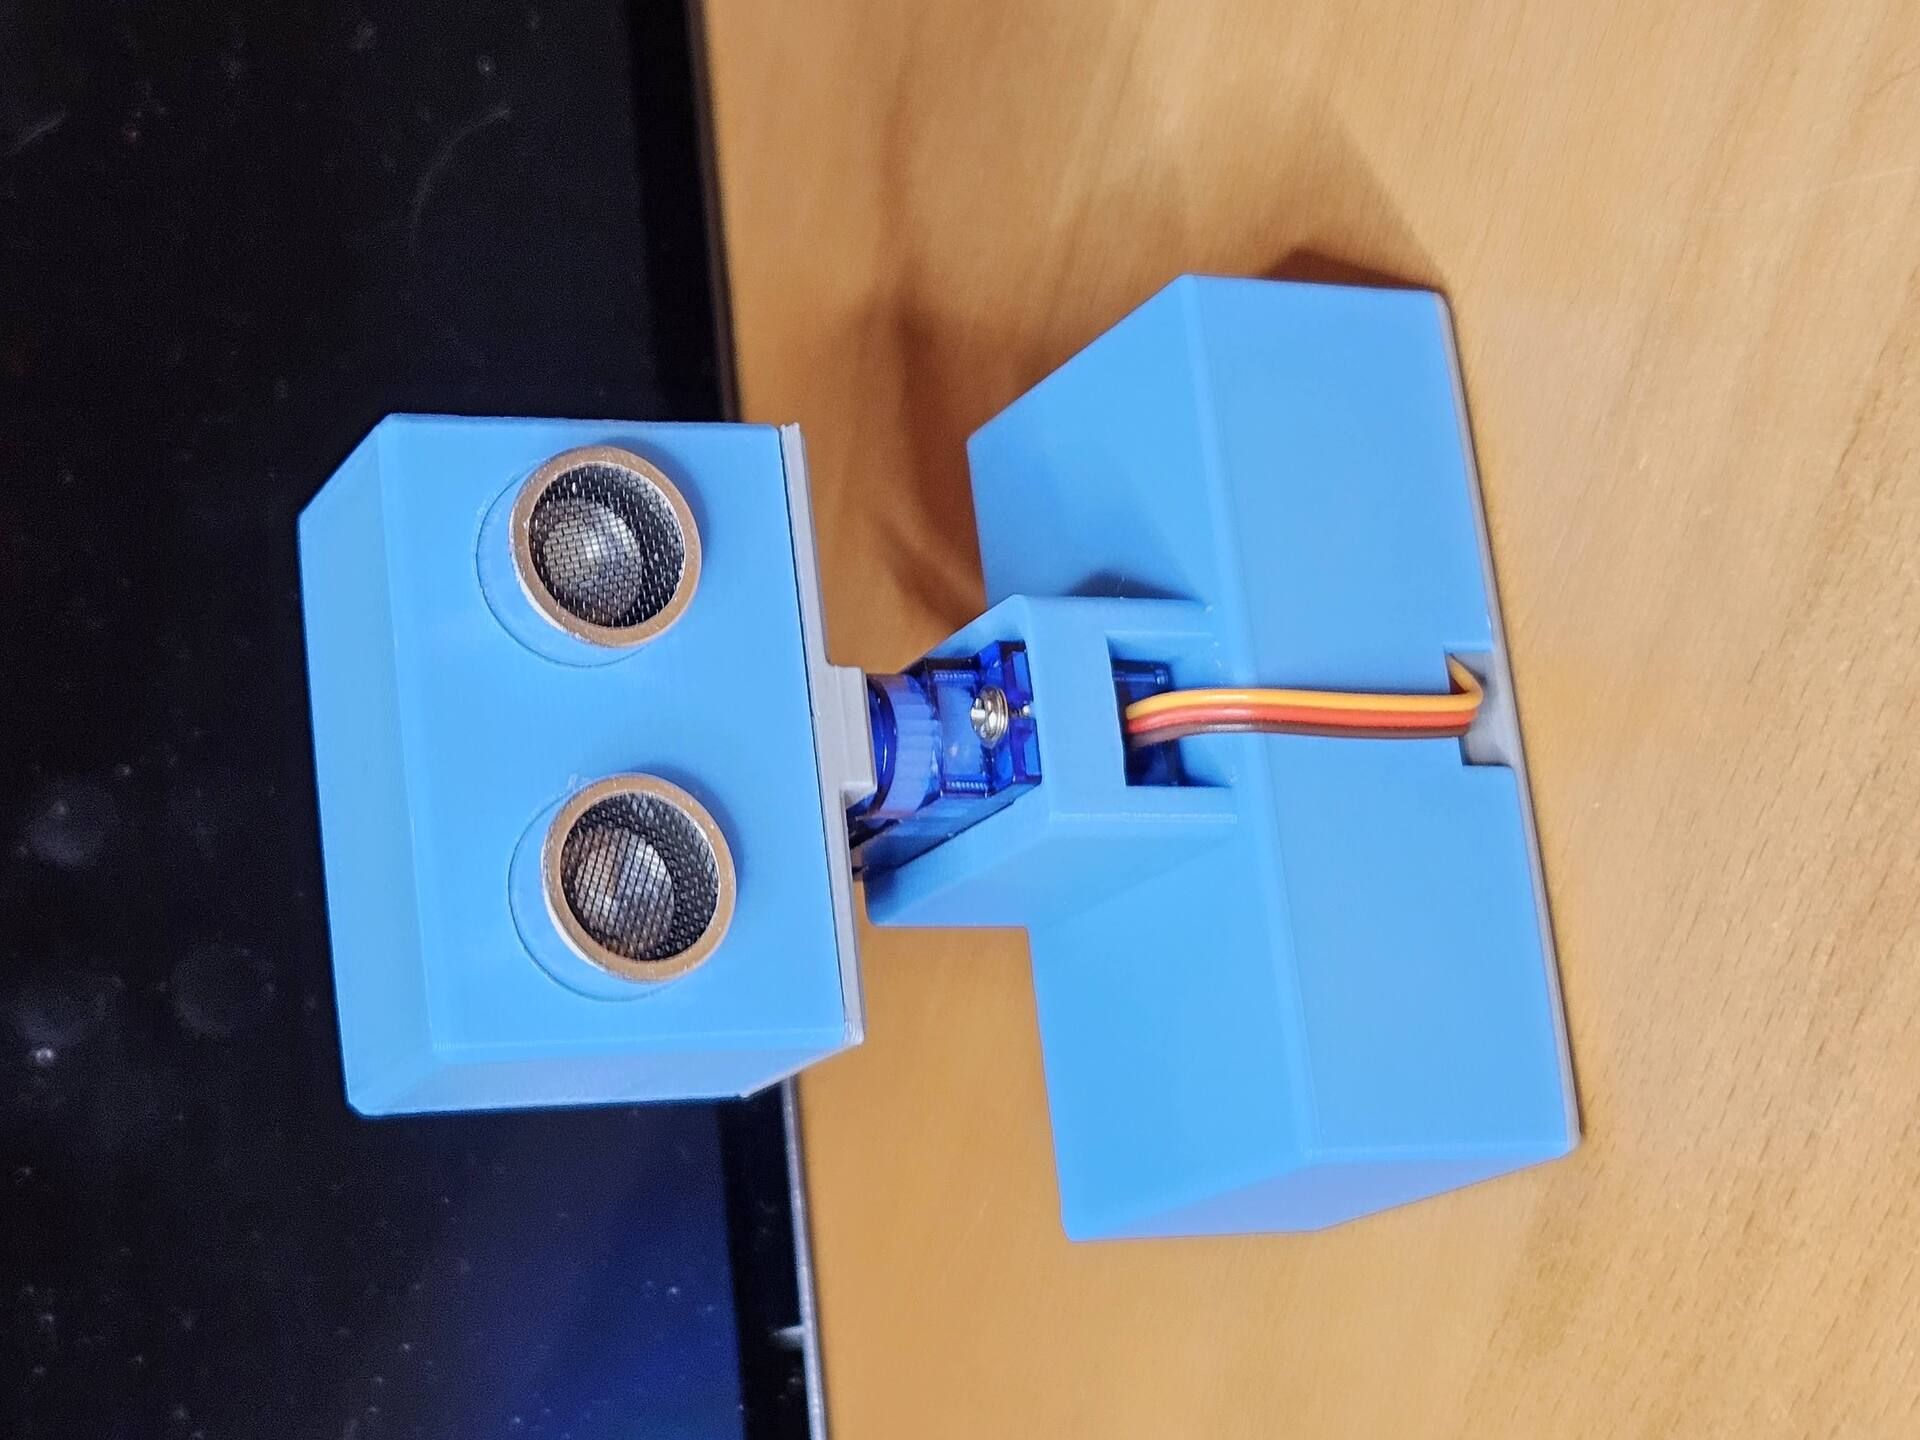
Robotic head with dual ultrasonic sonar grilles and the neck servo mount.
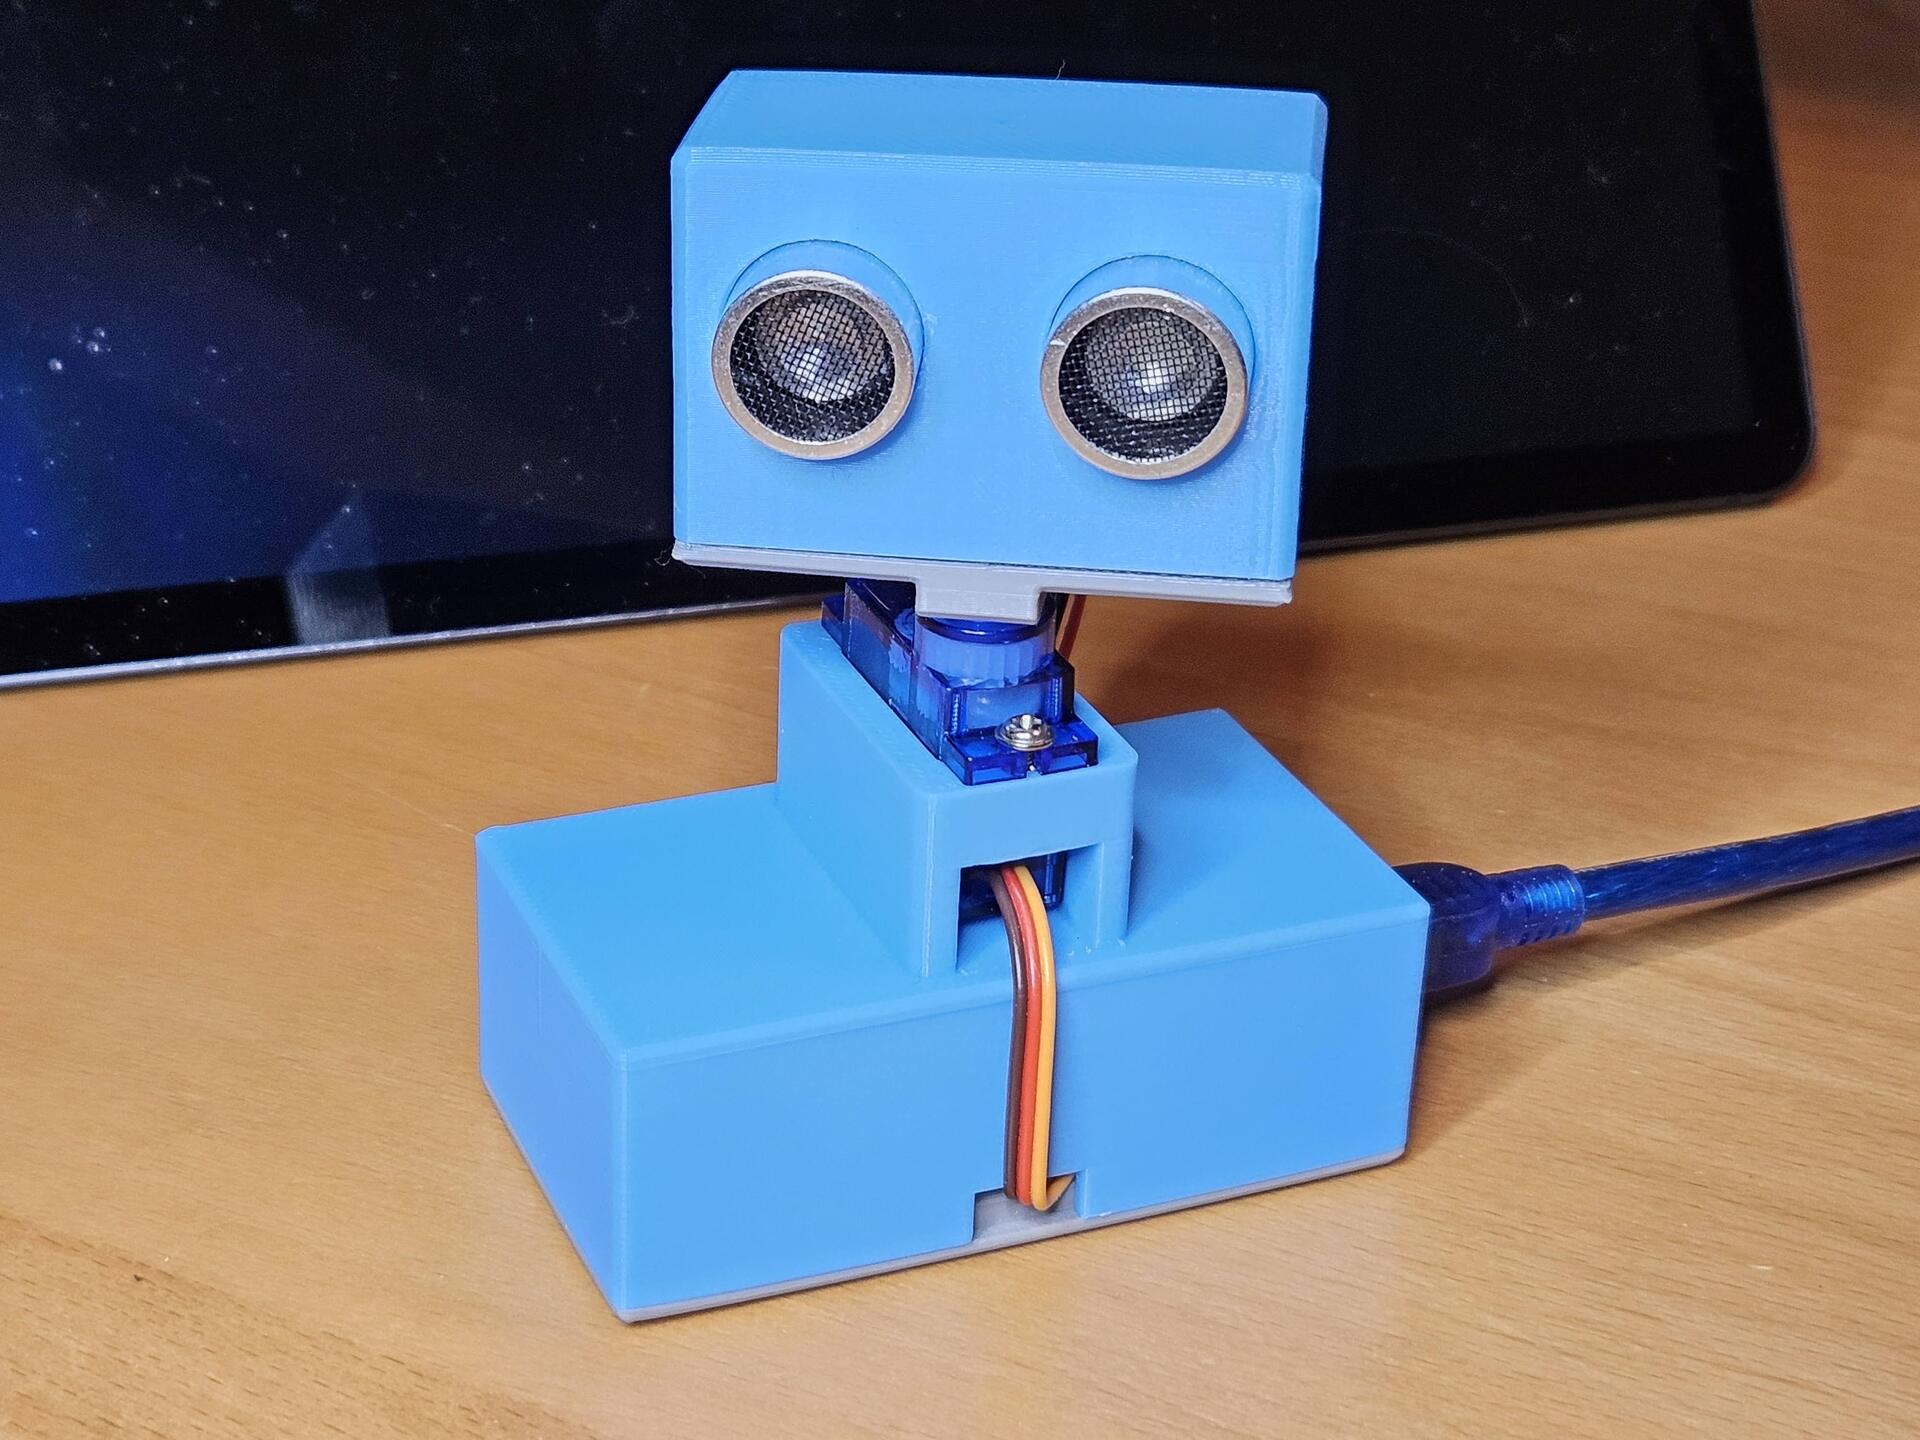
Side perspective highlighting cable routing and the base housing.
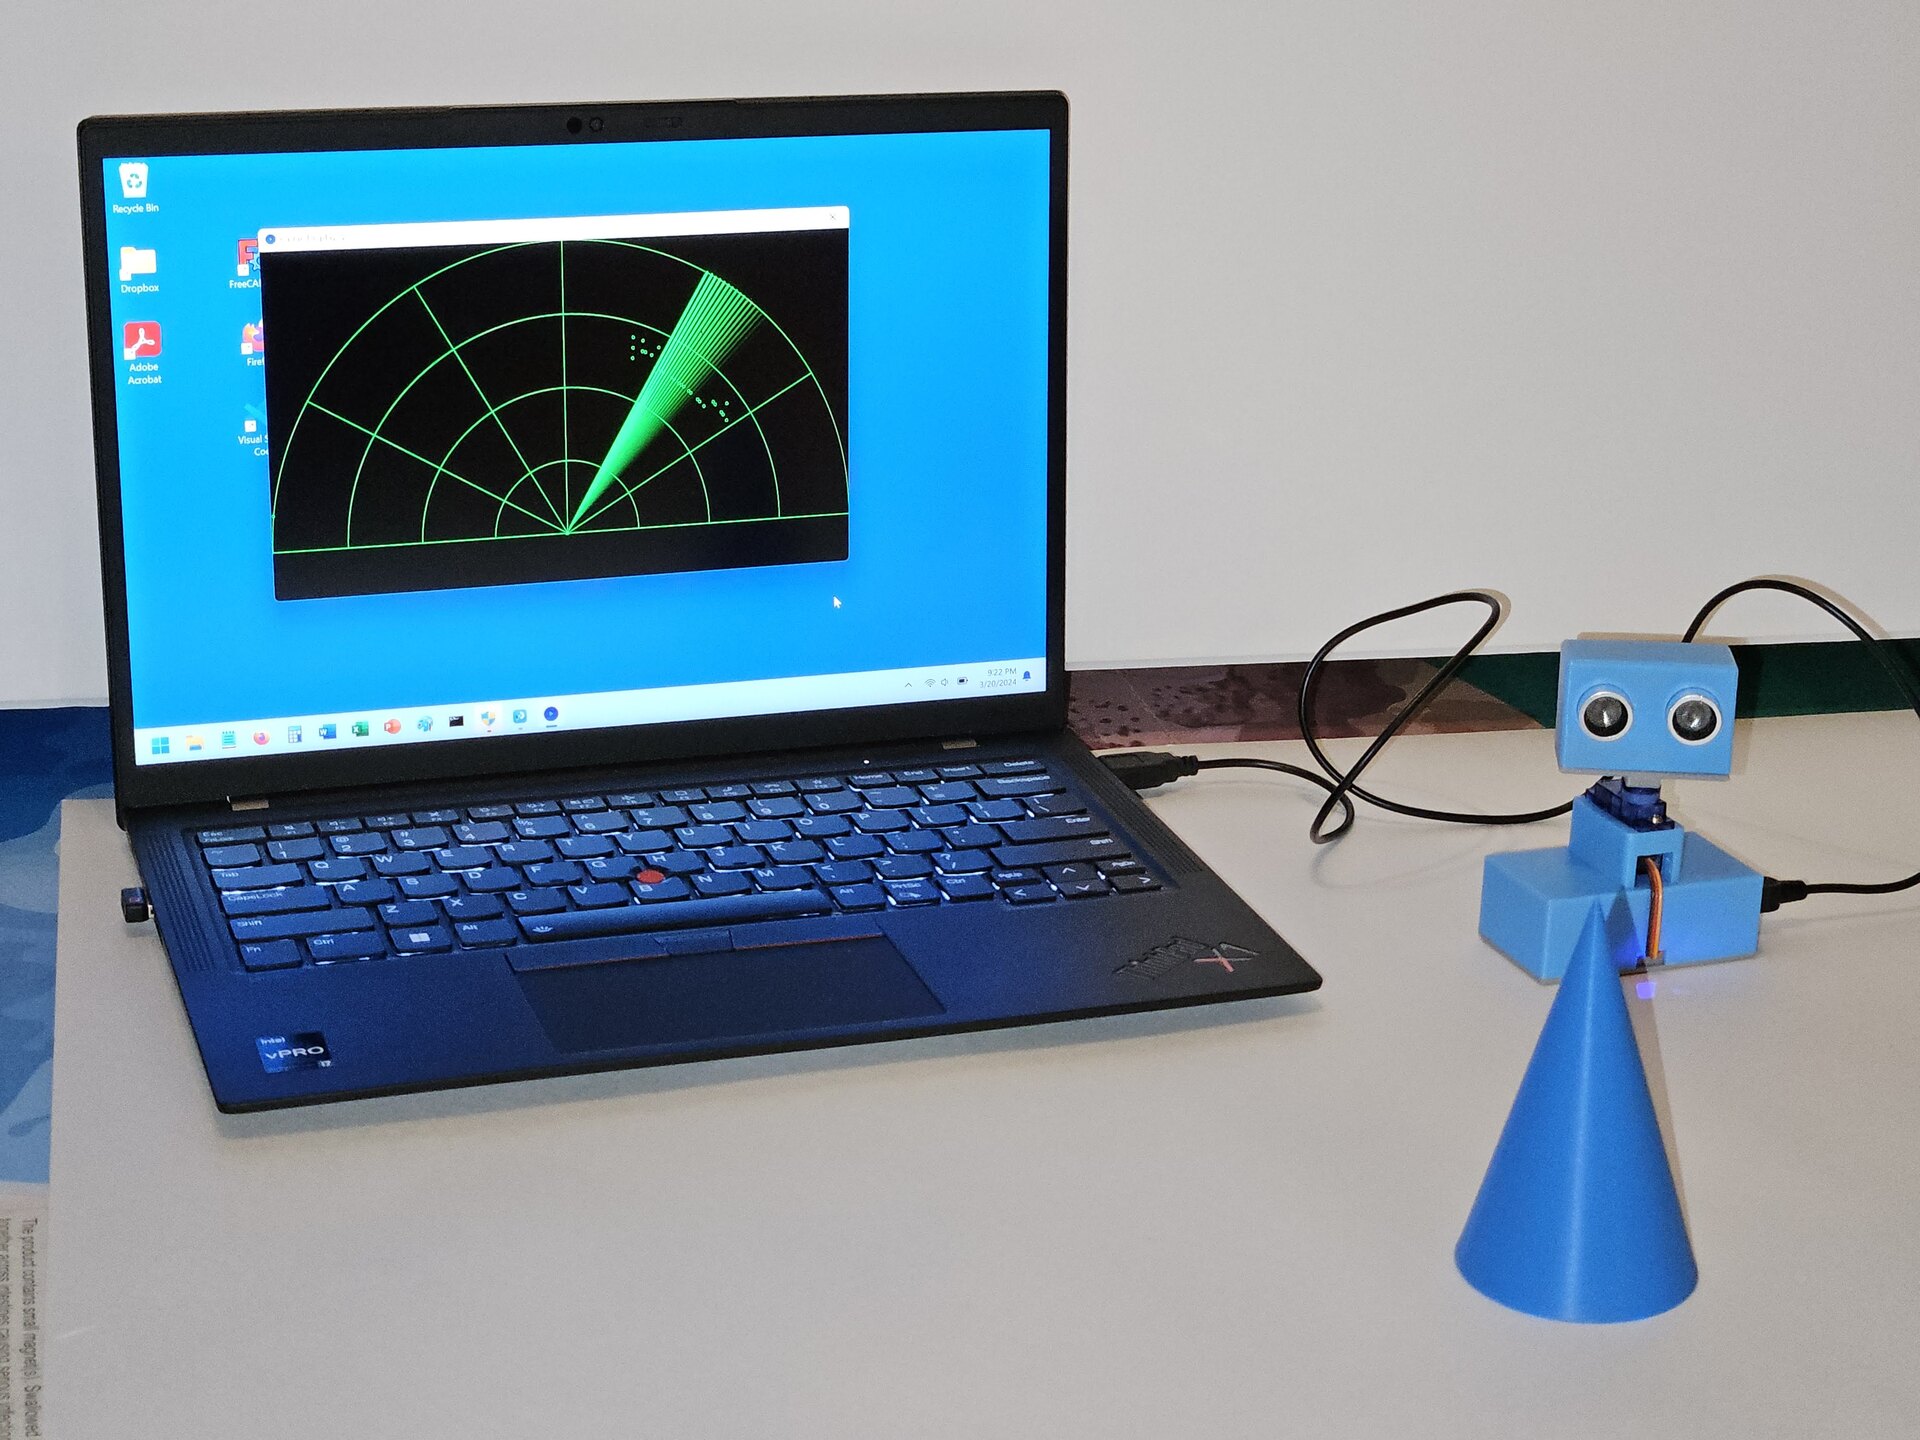
Full bench setup with the target cone and the PC radar application active.
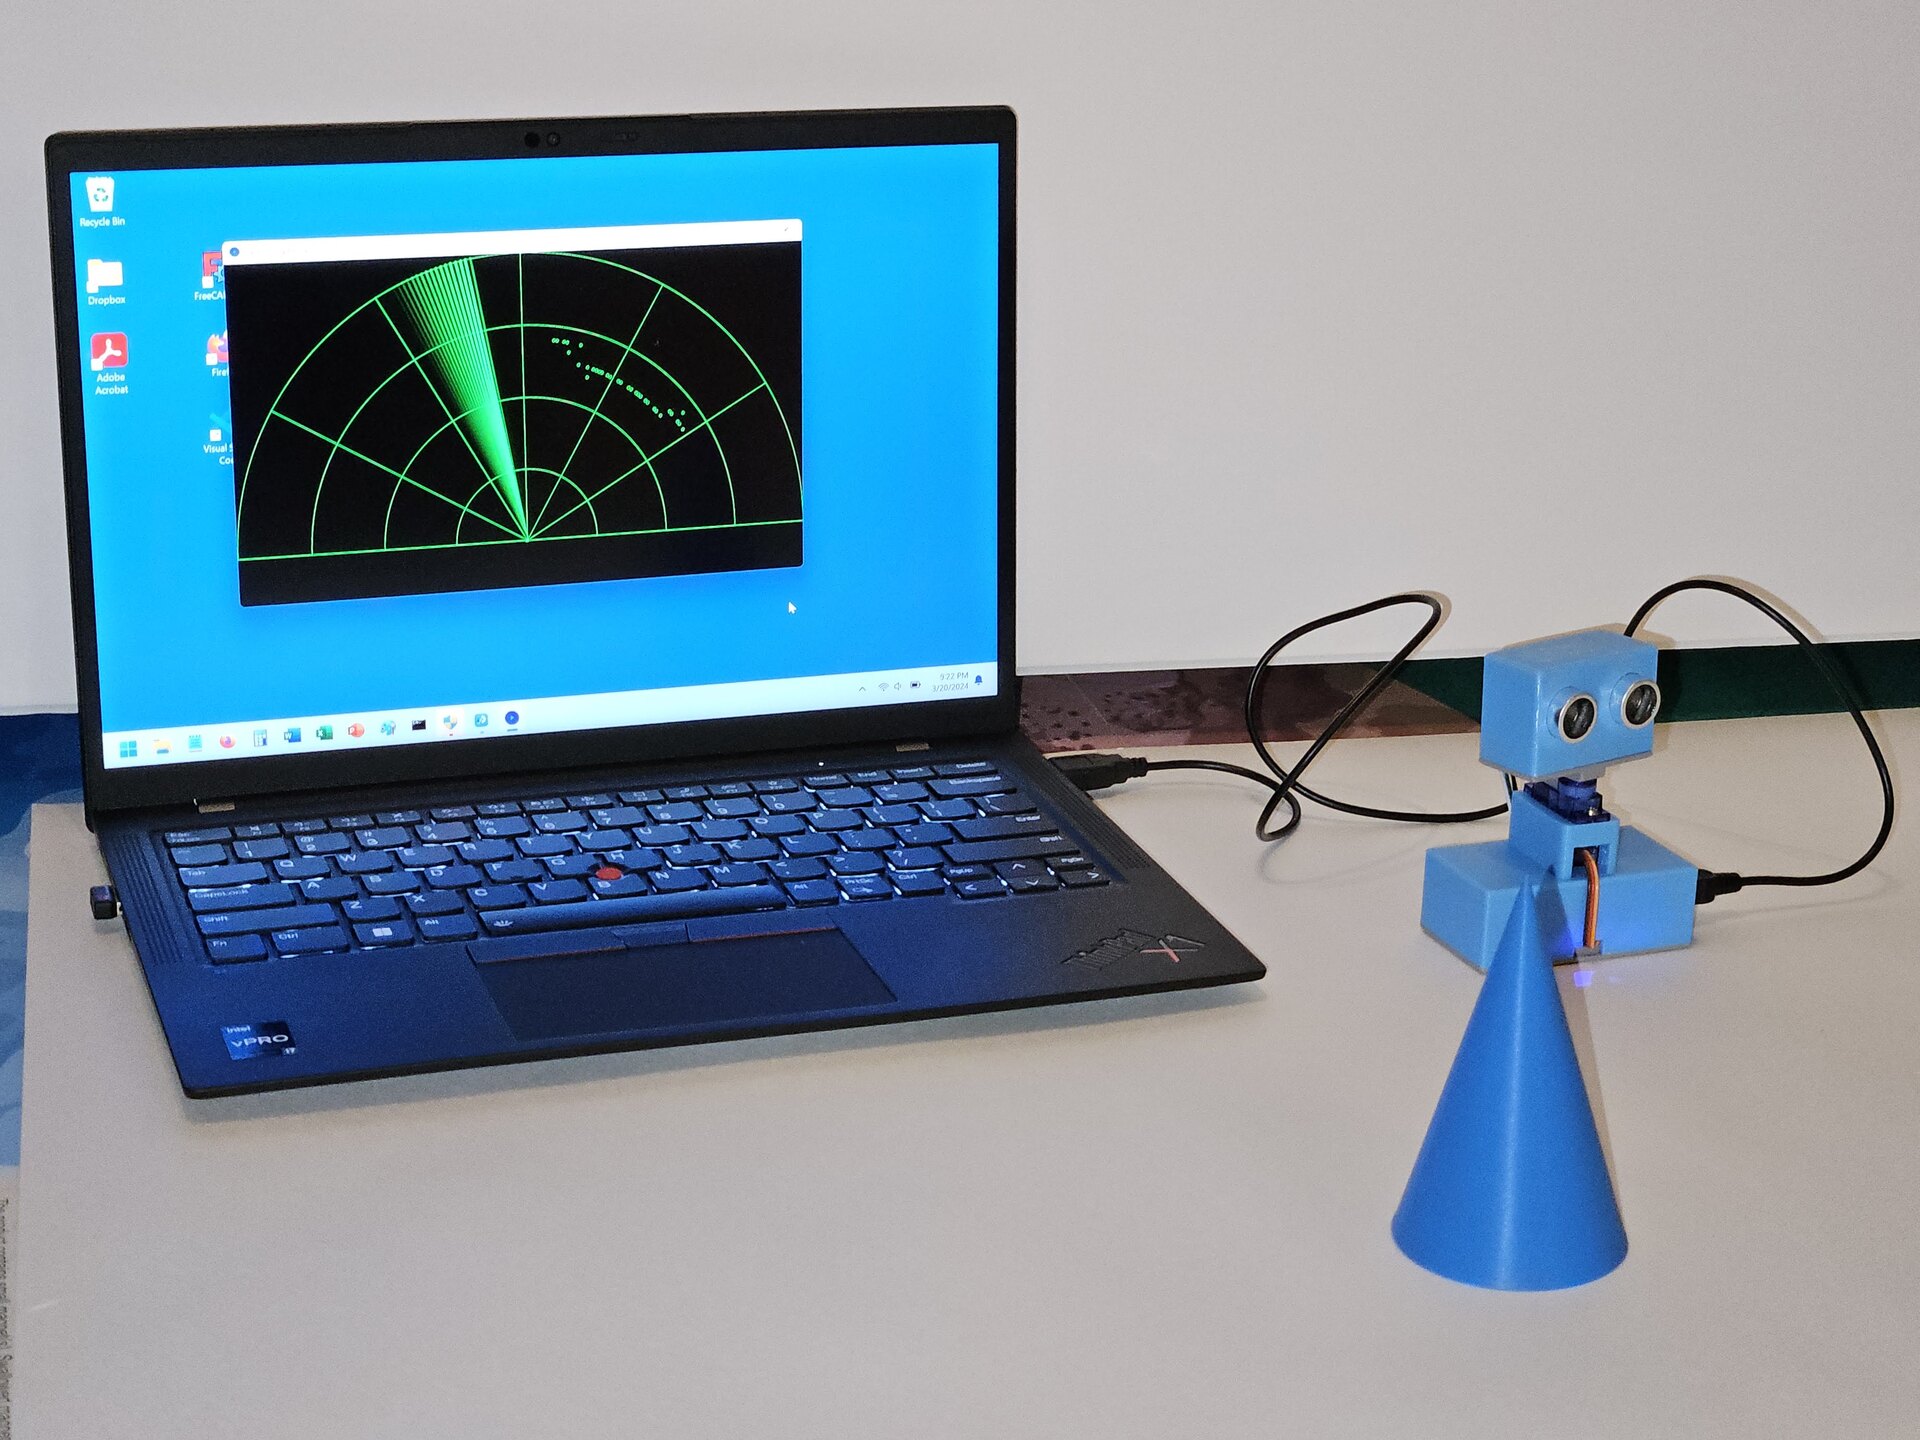
Desktop radar screen displaying a real-time target cluster.
4 photographs and drawings from this build.
| PARAMETER | SPECIFICATION / VALUE |
|---|---|
| Ultrasonic Sensor | HC-SR04 (40 kHz sonar transducer) |
| Detection Range | 2 cm to 400 cm |
| Scanning Field | 180° horizontal arc sweep |
| Servo Motor | SG90 9g micro servo (PWM driven) |
| Serial Telemetry | USB serial, 9600 bps |
| Frame / GUI | Custom polar radar interface with decaying target blips |
| Enclosure Material | 3D-printed custom PLA chassis |